

We propose UniTacHand, a novel unified representation to align robotic tactile information captured by dexterous hands with human hand touch signals obtained from gloves with sensors.
Key Concept
Enabling robotic hands to achieve human-level dexterous manipulation remains a significant challenge. While tactile sensing is crucial, its application is often hindered by the difficulty of collecting large-scale, real-world robotic tactile data. Learning from human demonstration (LfD) offers a promising alternative, but faces a fundamental mismatch between human haptic gloves and robotic tactile sensors.
To bridge this gap, UniTacHand projects disparate tactile signals onto a morphologically consistent 2D surface space of the MANO hand model. This unification standardizes heterogeneous data structures and embeds tactile signals with spatial context. We demonstrate that our approach achieves zero-shot tactile-based policy transfer and superior data efficiency via co-training on mixed human-robot data.
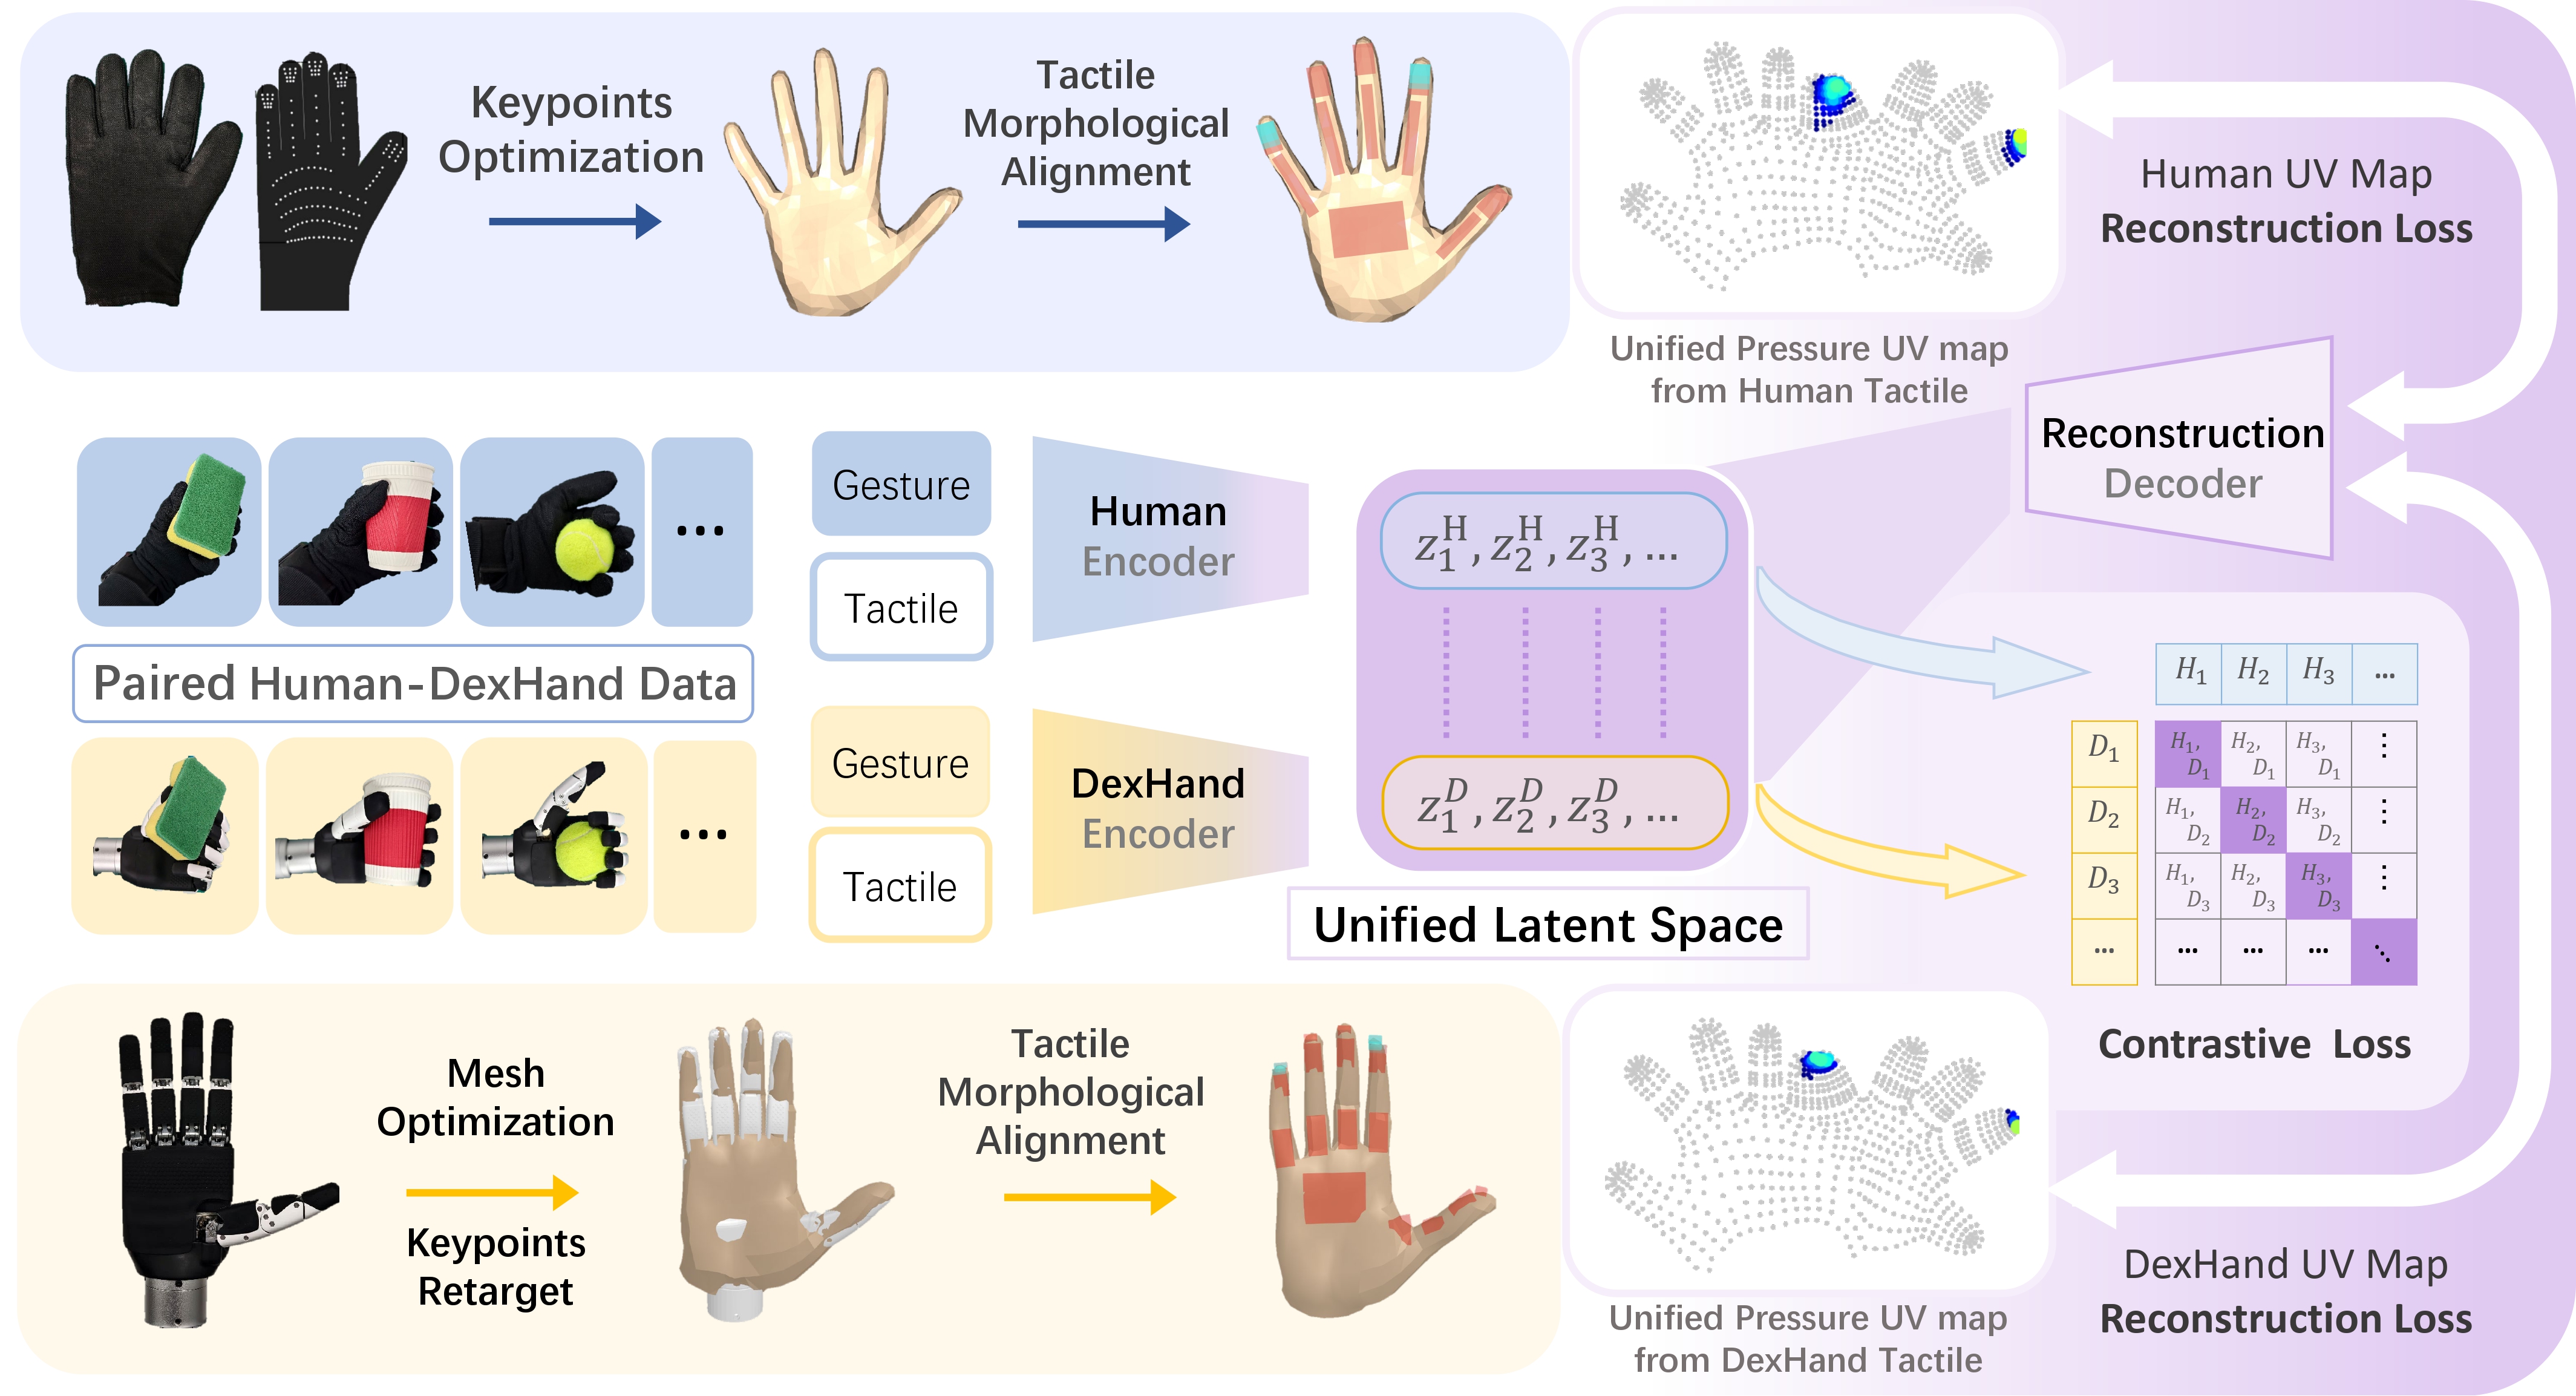
UniTacHand Framework Overview. (Left) Stage 1: Projecting tactile data from a human haptic glove or a robotic hand onto the unified MANO UV map. (Right) Stage 2: The contrastive learning framework with reconstruction and adversarial losses to align the latent spaces. The unified pressure UV maps serve as accurate prior knowledge to supervise domain-specific encoders.
Video Demo
Experiments
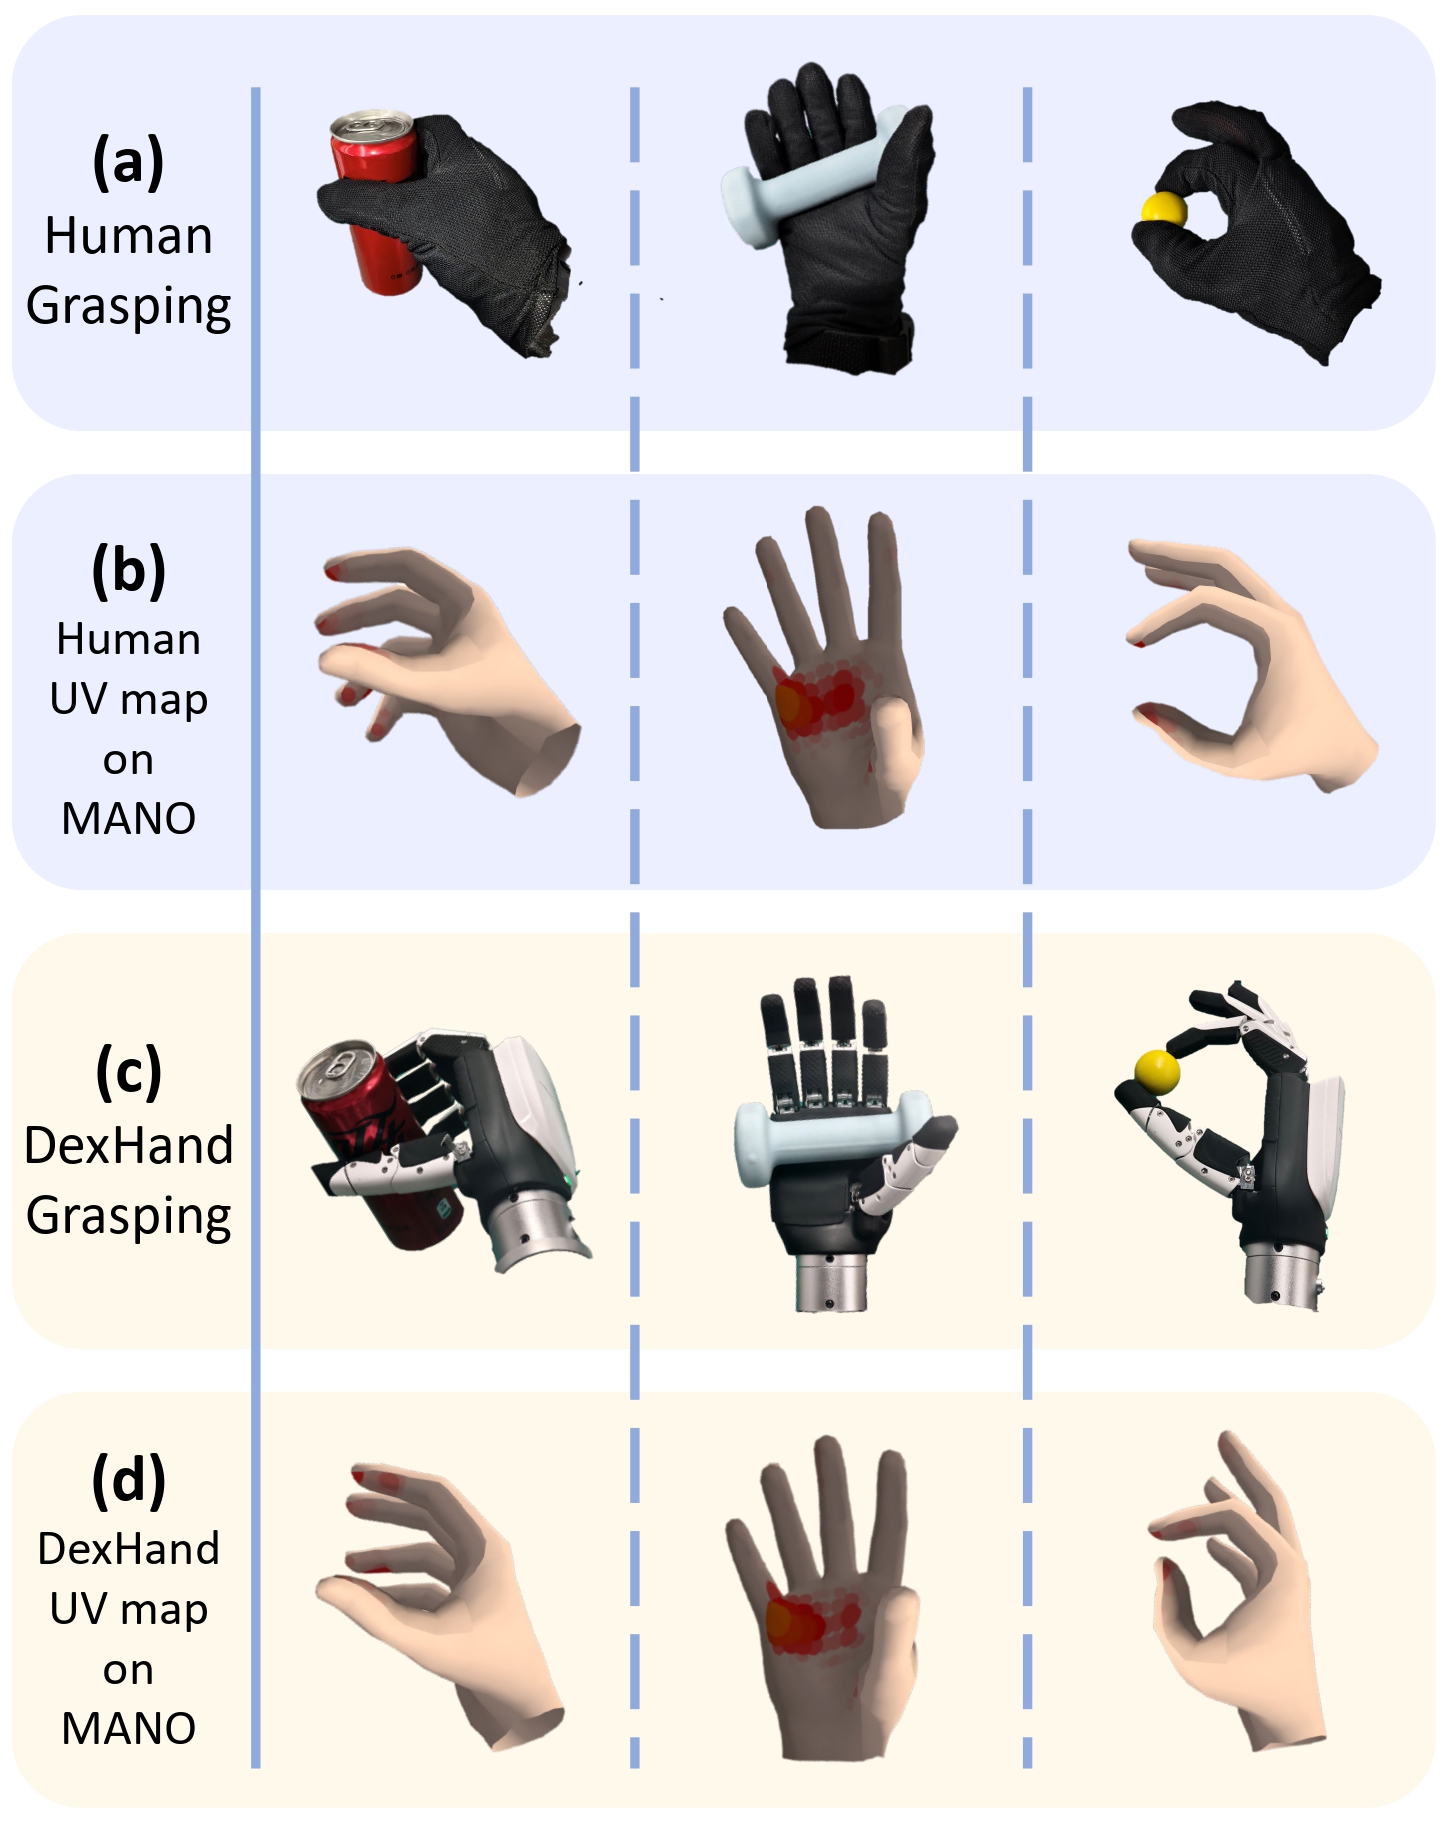
UV mapping Results: When a hand grasps an object, the activated tactile lattices on the MANO hand are highlighted in red. This achieves the unification of hand actions and spatial tactility, aligning human hands and dexterous hands in a shared tactile space.
Results of the tasks: CompliantControl and ObjectClassification. We calculate the accuracy (%) for each method.
| Tasks | PatchMatch | UV-Direct | UniTacHand (Ours) |
|---|---|---|---|
| CompliantControl | 10.0 | 36.0 | 40.0 |
| ObjectClassification (Human Set) | 43.2 | 71.6 | 59.5 |
| ObjectClassification (Robot Set) | 15.7 | 18.9 | 38.6 |
Success rates (%) for manipulation tasks comparing visual-only baselines and robot-only data.
| Data Source | Method | Success Rate |
|---|---|---|
| Robot Only | R-Visual-Only | 43.3 |
| R-Visual-Tactile | 50.0 | |
| Human + One-Shot | PatchMatch | 56.7 |
| UV-Direct | 63.3 | |
| UniTacHand (Ours) | 73.3 |
Citation
@article{unitachand,
  title={UniTacHand: Unified Spatio-Tactile Representation for Human to Robotic Hand Skill Transfer},
  author={Zhang, Chi and Cai, Penglin and Yuan, Haoqi and Xu, Chaoyi and Lu, Zongqing},
  journal={arXiv preprint arXiv:2512.21233},
  year={2025}
}